Six-Axis Articulated Robot (Educational, Collaborative)
Model SC-RA6 0500
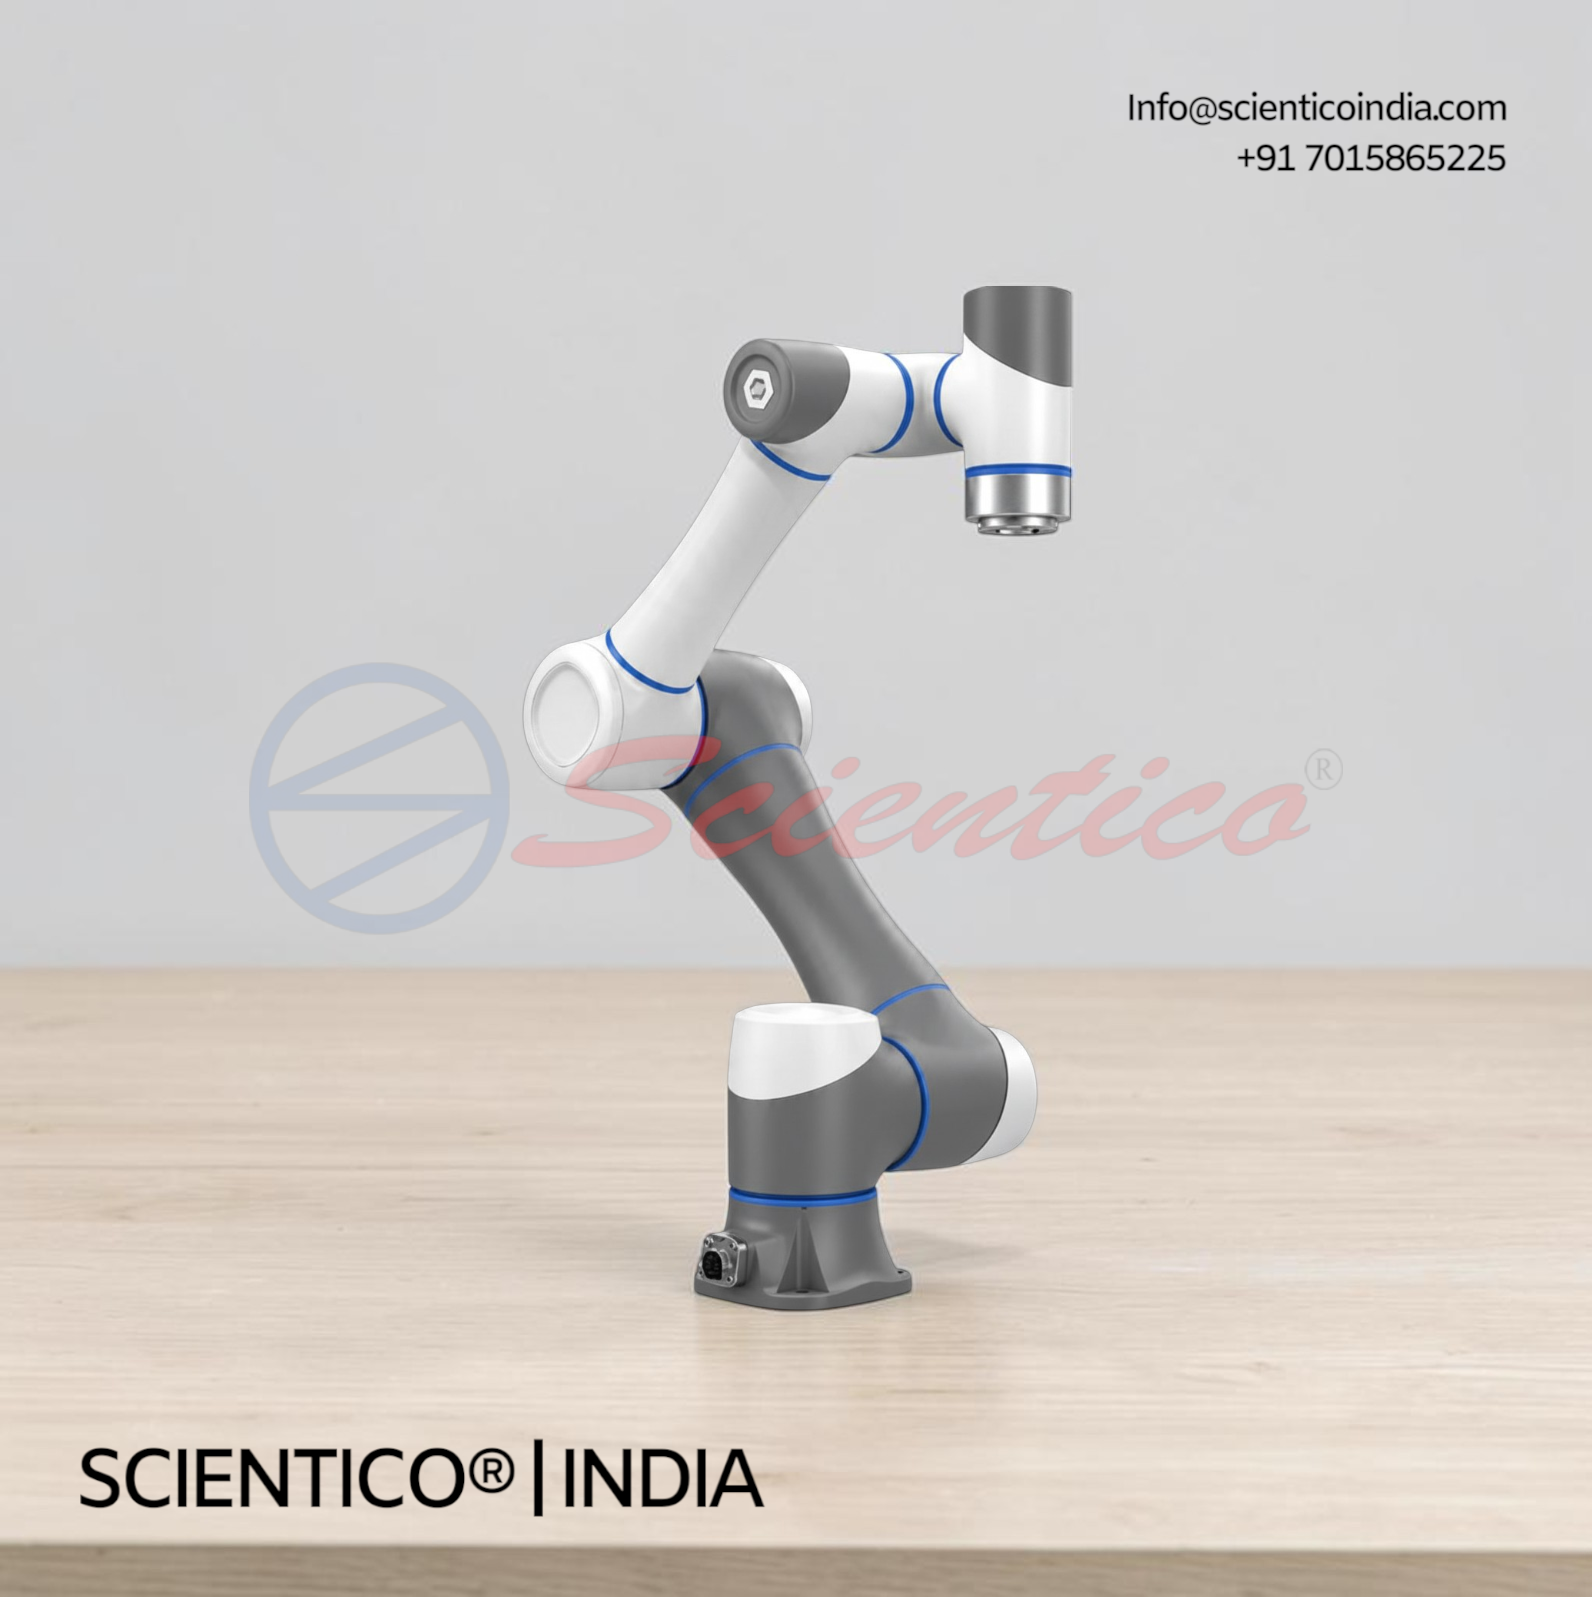
The Six-Axis Articulated Robot (Educational, Collaborative) – SC-RA6 0500 is a vertically articulated 6-axis tabletop robot with open-hardware joints that learners can dismantle and rebuild. It has a 1.5 kg payload, 600 mm reach, and ±0.05 mm repeatability, with DC servo drives on each joint. Tooling includes an electric parallel gripper, suction cup, and pen holder. The robot is ROS compatible and programmable in Python and C++. A 2 MP camera with object-detection software and 3D simulation are supplied under a room licence. Torque sensing and power limiting follow ISO 10218-1 and ISO/TS 15066, with an E-stop unit, IP54 rating, and CE marking. On-site assembly, commissioning, calibration, and 16 hours of train-the-trainer are included.
The Six-Axis Articulated Robot (Educational, Collaborative) – SC-RA6 0500 is a vertically articulated 6-axis tabletop robot of open-hardware design. Learners can dismantle and rebuild its joints, and it is programmable in Python and C++.
Product Overview
The Six-Axis Articulated Robot (Educational, Collaborative) – SC-RA6 0500 is a vertically articulated 6-axis tabletop robot with open-hardware design, so learners can dismantle and rebuild its joints. It has a payload of 1.5 kg at full extension and a reach of 600 mm, with repeatability of ±0.05 mm. Each joint has a precision DC servo drive with an independent joint controller. Tooling includes an electric parallel gripper, a suction cup, and a pen holder. The embedded controller in the base supports ROS, Wi-Fi, Ethernet, and a Python and C++ API. Communication options include TCP/IP, Modbus TCP and RTU, and a 50-pin D-sub PLC interface compatible with the S7-1200. A 2 MP USB camera with bracket and object-detection software is supplied under a room licence, along with 3D simulation software for offline programming. The robot uses torque sensing and power limiting, with test evidence to ISO 10218-1 and ISO/TS 15066. It includes an E-stop unit, is rated IP54, and is documentation reviewed per model. Service includes on-site assembly, commissioning, calibration, and 16 hours of train-the-trainer support.
Six-Axis Articulated Robot (Educational, Collaborative) – SC-RA6 0500: Technical Specifications
| Category | Specification |
|---|---|
| Robot Type | Vertically articulated, 6-axis, tabletop |
| Design | Open hardware; joints can be dismantled and rebuilt |
| Payload | 1.5 kg at full extension |
| Reach | 600 mm |
| Repeatability | ±0.05 mm |
| Drives | Precision DC servo per joint with independent joint controller |
| Tooling | Electric parallel gripper; suction cup; pen holder |
| Controller | Embedded in base |
| Programming | ROS; Python and C++ API |
| Connectivity | Wi-Fi; Ethernet |
| Communication | TCP/IP; Modbus TCP and RTU; 50-pin D-sub PLC interface; S7-1200 compatible |
| Vision | 2 MP USB camera with bracket; object-detection software; room licence |
| Torque Sensing | Power limiting and torque sensing to ISO 10218-1 and ISO/TS 15066, with test evidence |
| Emergency Stop | E-stop unit |
| Ingress Protection | IP54 |
| Simulation | 3D simulation for offline programming; room licence |
| Compliance | documentation reviewed per model |
| Service | On-site assembly, commissioning and calibration; 16 h train-the-trainer |
Key Features
- Open-Hardware Design: learners can dismantle and rebuild the joints
- Six-Axis Motion: vertically articulated tabletop arm
- Collaborative Safety: torque sensing and power limiting with test evidence
- Precision Drives: DC servo per joint with independent joint controllers
- Multiple Tools: electric parallel gripper, suction cup, and pen holder
- ROS Compatible: Python and C++ programming support
- Industrial Connectivity: TCP/IP, Modbus TCP and RTU, and S7-1200 compatible PLC interface
- Vision System: 2 MP USB camera with object-detection software
- Offline Programming: 3D simulation software included
- On-Site Support: assembly, commissioning, calibration, and train-the-trainer
Experiments
- Forward and inverse kinematics of a six-axis arm
- Joint dismantling, reassembly and calibration
- Pick-and-place using the electric parallel gripper
- Suction cup handling of objects
- Drawing with the pen holder
- Python and C++ programming of robot motion
- ROS-based robot control and messaging
- Object detection using the 2 MP camera and vision software
- Offline programming and motion verification in 3D simulation
- Modbus and TCP/IP communication with the robot controller
- PLC control of the robot through the S7-1200 compatible interface
- Torque sensing and power limiting response during contact
Construction and Design
The Six-Axis Articulated Robot (Educational, Collaborative) – SC-RA6 0500 is a vertically articulated tabletop arm with six joints. Each joint is driven by a precision DC servo with its own joint controller. The embedded controller sits in the base. The joints are designed to be dismantled and rebuilt for learning. A 1.5 kg payload and 600 mm reach define its working envelope. Tooling is interchangeable between the electric parallel gripper, suction cup, and pen holder. A 2 MP camera mounts on a bracket. The robot is rated IP54.
Software
ROS compatibility, Python and C++ API, 3D simulation software for offline programming, and object-detection software are included. The simulation and vision software are supplied under a room licence.
Scope of Delivery
- 6-axis robot with base frame
- Gripper and tool set
- Camera with vision software
- Simulation software
- Cables and calibration tools
- English teacher and student manuals
Q: What are the payload and reach?
A: The robot has a payload of 1.5 kg at full extension and a reach of 600 mm, with repeatability of ±0.05 mm.
Q: Can learners take the robot apart?
A: Yes. The robot is of open-hardware design, so learners can dismantle and rebuild its joints.
Q: Which programming languages are supported?
A: The robot supports Python and C++ through its API, and is ROS compatible.
Q: What safety features are included?
A: The robot uses torque sensing and power limiting, with test evidence to ISO 10218-1 and ISO/TS 15066. It has an E-stop unit and is rated IP54.
Q: Which PLC and network interfaces are available?
A: The robot supports TCP/IP, Modbus TCP and RTU, and a 50-pin D-sub PLC interface compatible with the S7-1200. Wi-Fi and Ethernet are also available.
Need Assistance? We're Here to Help!
Connect with our team for product specifications, pricing, and customized solutions for your institution or project.