
Magnetic Levitation Control Trainer | NexuMation 08
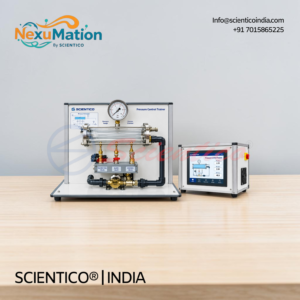
The Magnetic Levitation Control Trainer NexuMation 08 is a single degree of freedom electromagnetic system that levitates a small magnetic ball in midair. This magnetic levitation control trainer uses a linear Hall effect sensor for position measurement and an overhead electromagnet with 20mm coil diameter. Control range is 1 – 15mm with a control air gap of 15mm. Acquisition sampling frequency is up to 3.8KHz with 12-Bit A/D resolution at 28KS/s. It is fully compatible with MATLAB/Simulink and includes an integrated power supply.
The Magnetic Levitation Control Trainer NexuMation 08 is a single degree of freedom electromagnetic system. It controls the magnetic field of an electromagnet to levitate a small magnetic ball in midair. This magnetic levitation control trainer is a classic electro-mechanical experiment with interesting nonlinear dynamics and control challenges.
Product Overview
The Magnetic Levitation system is a classic electro-mechanical experiment. The small magnetic ball levitates in the air indefinitely without any disturbance.
The overhead electromagnet is wound in coil. It generates an attractive force on the magnetic ball that initially sits on the post. The total air gap or travel distance between the ball and the magnet, when initially on the post, is 14 mm.
The vertical position of the ball is measured using a linear Hall effect sensor. The current in the electromagnet is controlled using a controller.
The relationship between the electromagnet and the ball is highly nonlinear. The electromagnet’s own dynamic behavior adds to this complexity. This makes the magnetic levitation control trainer an ideal platform for teaching modeling, linearization, current control, position control, and cascade control. It also supports advanced strategies such as multi-variable control, gain scheduling, and nonlinear control.
Magnetic Levitation Control Trainer NexuMation 08: Technical Specifications
| Parameter | Value |
|---|---|
| Degrees of Freedom | 1 |
| System Type | Electromagnetic based |
| Levitated Object | Small magnetic ball |
| Travel Distance on Post | 14 mm |
| Power Supply | Integrated |
| Electromagnet | Installed |
| Lights | Installed |
| Position Sensor | Linear Hall effect sensor, installed |
| Data Acquisition Card | Provided with Simulink Library |
| Communication Interface | RS232 |
| Serial Card | PCI Serial Card included |
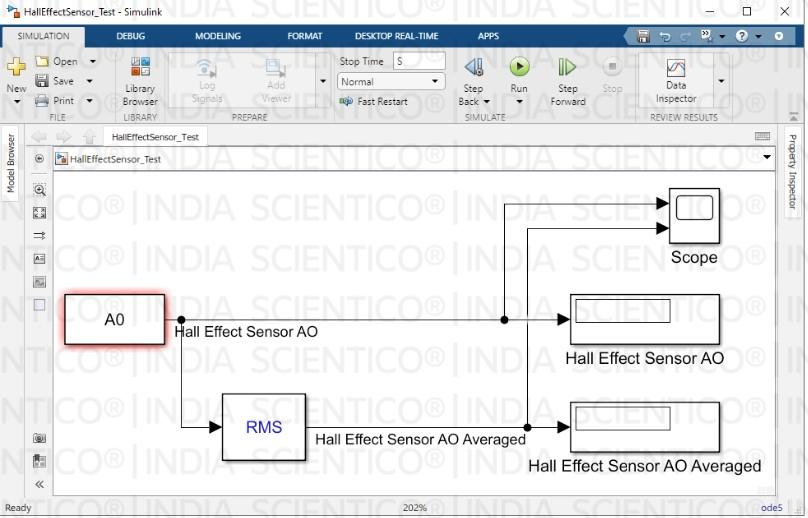
| Software Compatibility | Fully compatible with MATLAB/Simulink |
Technical Data
| Parameter | Value |
|---|---|
| Coil Diameter | 20mm |
| Control Air gap | 15mm |
| Acquisition Sampling Frequency | Up to 3.8KHz |
| A/D Resolution | 12-Bit |
| A/D Sampling Rate | 28KS/s |
| Control Range | 1 – 15mm |
Key Features
- Power Supply: integrated
- Electromagnet: installed
- Lights: installed
- Position Sensor: linear Hall effect, installed
- Application: magnetic levitation control trainer for nonlinear control teaching
- Data Acquisition Card: provided with Simulink Library
- Communication: RS232 interface, PCI Serial Card included
- Software: fully compatible with MATLAB/Simulink
- Sampling Frequency: up to 3.8KHz
- A/D Resolution: 12-Bit, 28KS/s sampling rate
- Control Range: 1 – 15mm
Experiments
- Magnetic Levitation Control description
- System modeling experiment and analysis
- System open-loop response analysis
- PID controller design
- Root locus analysis and control
- State space model and control
Construction and Design
The Magnetic Levitation Control Trainer NexuMation 08 is a single degree of freedom electromagnetic system. An overhead electromagnet is wound in coil. The coil diameter is 20mm.
The electromagnet generates an attractive force on the magnetic ball. The ball initially sits on the post. The air gap between the ball and the magnet at this position is 14 mm.
A linear Hall effect sensor measures the vertical position of the ball. A controller regulates the current in the electromagnet. Lights and an integrated power supply are installed.
This magnetic levitation control trainer has a control air gap of 15mm and a control range of 1 – 15mm.
Software
- Data Acquisition Card provided with Simulink Library
- Fully compatible with MATLAB/Simulink
Required for Operation
- PC with Windows 7 or later (recommended Windows 10) and an available serial port or an expansion slot for a serial card (not included)
- MATLAB R2020b or later with Simulink, MATLAB Coder, Simulink Coder, and Simulink Desktop Real-Time (not included)
Q1. How does the magnetic levitation control trainer levitate the ball?
An overhead electromagnet wound in coil generates an attractive force on the magnetic ball. The current in the electromagnet is controlled using a controller.
Q2. How is the ball position measured?
The vertical position is measured using a linear Hall effect sensor.
Q3. What is the control range?
The control range is 1 – 15mm. The control air gap is 15mm.
Q4. Which control topics can be taught on this trainer?
Modeling, linearization, current control, position control, and cascade control. Multi-variable control, gain scheduling, and nonlinear control are also supported.
Q5. What is required to run the trainer?
A PC with Windows 7 or later (recommended Windows 10) and a serial port or serial card expansion slot. MATLAB R2020b or later with the listed toolboxes is also required. MATLAB and its toolboxes are not included.
Need Assistance? We're Here to Help!
Connect with our team for product specifications, pricing, and customized solutions for your institution or project.