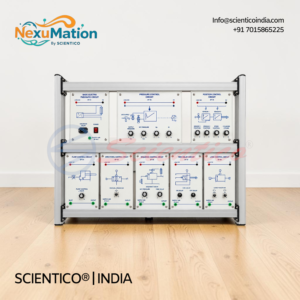


Ball & Beam Control Trainer | NexuMation 05
The Ball & Beam Control Trainer NexuMation 05 controls a stainless-steel ball position on a 400mm track using a DC motor and adjustable beam angle. This ball and beam control trainer features a 1000 lines per revolution optical encoder, 1:4 gear ratio, and linear potentiometer position measurement. On-board sensors, control circuits, drivers, and protection circuits are installed. MATLAB control interface includes PID control, digital encoder, and DC power supply modules for automatic control principle and modern control engineering courses.
The Ball & Beam Control Trainer NexuMation 05 is specially designed for courses in automatic control principle, modern control engineering, and electrical motor control. This ball and beam control trainer controls the position of a stainless-steel ball on the track by adjusting the rotating angle of a beam.
Product Overview
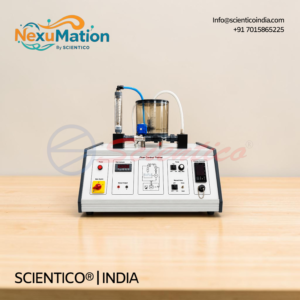
The Ball & Beam Control Trainer NexuMation 05 consists of two parts: the Ball & Beam body and the control system.
The system controls the position of a stainless-steel ball on the track. This is achieved by adjusting the rotating angle of a beam. The beam is driven by a DC motor. An optical encoder with 1000 lines per revolution measures motor rotation. The gear ratio is 1:4.
The ball moves along a linear track with a moving range of 400mm. Position is measured using a linear potentiometer.
All sensors are installed on-board. Control circuits, drivers, and protection circuits are installed. An intelligent motion controller manages the system.
The ball and beam control trainer includes MATLAB control interface with PID control module, digital encoder module, and DC power supply module.
Ball & Beam Control Trainer NexuMation 05: Technical Specifications
| Parameter | Value |
|---|---|
| Motor Type | DC |
| Optical Encoder | 1000 lines/revolution |
| Gear Ratio | 1:4 |
| Moving Range | 400mm |
| Position Measurement | Linear Potentiometer |
| Controller | Intelligent Motion Controller |
| Sensors | Installed on-board |
| Control Circuits | Installed |
| Drivers | Installed |
| Protection Circuits | Installed |
| Software Interface | MATLAB Control Interface |
Technical Data
| Parameter | Value |
|---|---|
| Motor | DC |
| Optical Encoder | 1000 lines/revolution |
| Gear Ratio | 1:4 |
| Moving Range | 400mm, Linear Potentiometer |
Key Features
- Motor: DC
- Application: ball and beam control trainer for automatic control principle and modern control engineering courses
- Sensors: installed on-board
- Control Circuits: installed
- Drivers: installed
- Protection Circuits: installed
- Optical Encoder: 1000 lines per revolution
- Gear Ratio: 1:4
- Moving Range: 400mm with linear potentiometer measurement
- Controller: intelligent motion controller
- Software Interface: MATLAB control interface
Experiments Included
- Ball & Beam Features & Benefits
- Ball & Beam Functional Components
- Mechanical Model of Ball & Beam
- Modeling The Ball and Beam Experiment in Simulink
- Electrical Model
- Open-Loop Model of Ball & Beam System
- Ball & Beam Control Using PID
- Root Locus Method
- Frequency Response Method
Control Modules
- PID control module
- Digital Encoder module
- DC power supply module
Construction and Design
The Ball & Beam Control Trainer NexuMation 05 is a two-part system comprising the Ball & Beam body and the control system. The stainless-steel ball moves on a track. A DC motor drives a beam. The rotating angle of the beam is adjusted to control the ball position.
The ball and beam control trainer has a moving range of 400mm. Position is measured using a linear potentiometer. The DC motor is coupled to the beam via a gear ratio of 1:4. An optical encoder with 1000 lines per revolution measures motor rotation.
All sensors are installed on-board. Control circuits, drivers, and protection circuits are installed on the system. An intelligent motion controller manages operations. This ball and beam control trainer allows real-time feedback and control.
Software
- MATLAB Control Interface
- PID control module
- Digital Encoder module
- DC power supply module
Q1. What does the Ball & Beam Control Trainer NexuMation 05 control?
It controls the position of a stainless-steel ball on the track by adjusting the rotating angle of a beam.
Q2. How is the ball position measured?
Position is measured using a linear potentiometer. The moving range is 400mm.
Q3. How is the beam driven?
A DC motor drives the beam. The motor is coupled via a gear ratio of 1:4. An optical encoder with 1000 lines per revolution measures motor rotation.
Q4. Which control methods are taught?
PID control, root locus method, and frequency response method are included.
Q5. What is included in the ball and beam control trainer?
Sensors installed on-board, control circuits, drivers, protection circuits, an intelligent motion controller, and MATLAB control interface with PID control, digital encoder, and DC power supply modules.
Need Assistance? We're Here to Help!
Connect with our team for product specifications, pricing, and customized solutions for your institution or project.